Andrew Davison
Also known as Andrew John Davison
Andrew Davison is a professor of robot vision at Imperial College London whose computer-vision research helps robots map and understand real spaces. He studied physics at Oxford, completed a DPhil in its Active Vision Lab, and researched robot navigation in Japan. His MonoSLAM system enabled real-time, single-camera 3D localisation and mapping, and his work with Dyson brought SLAM algorithms to the 360 Eye robot vacuum. He was elected a Fellow of the Royal Academy of Engineering in 2017 and the Royal Society in 2023; in 2025, he coauthored 4DTAM for tracking and mapping dynamic 4D scenes.
- Now at
- Imperial College London
- Works
- 213
- Citations
- 31,261
- h-index
- 66
- Badges
Publication numbers from OpenAlex, as of 22 October 2026.
Timeline
-
1991–1998
Physics and an Oxford DPhil
He grows up in Kent and studies physics at Oxford from 1991 to 1994, earning a first-class BA. In October 1994, he begins a DPhil in the Active Vision Lab under David Murray and completes it in February 1998.
-
1998–2001
Vision research in Japan and Oxford
Starting in February 1998, he goes to Japan on a two-year European Union Science and Technology Fellowship and researches vision-based navigation at AIST’s Intelligent Systems Institute. In May 2000, he returns to Oxford and works with Ian Reid on markerless human motion capture through September 2001, while continuing SLAM research.
-
2002–2007
MonoSLAM and Imperial
He holds an EPSRC Advanced Research Fellowship from 2002 to 2007 and joins Imperial as a lecturer in May 2005. His 2003 MonoSLAM system enables robust, drift-free, real-time 3D localisation and mapping with a single camera.
-
2014–2016
Dyson backs robot vision
In February 2014, Dyson commits £5 million to Andrew Davison’s Robot Vision Research Group at Imperial for domestic-robot research. He leads work on vision systems that help robots understand and adapt to their surroundings. The Dyson 360 Eye goes on sale worldwide in 2016, with Davison’s core SLAM algorithms at its heart.
-
2017
Royal Academy fellowship
In September 2017, Imperial reports his election to the Royal Academy of Engineering; he is one of 50 new Fellows admitted at its annual general meeting. He directs the £5 million Dyson Robotics Laboratory at Imperial.
-
2023
Royal Society fellowship
In May 2023, he is elected a Fellow of the Royal Society while serving as Professor of Robot Vision in Imperial’s Department of Computing.
-
2025
4DTAM for dynamic scenes
In 2025, he coauthors 4DTAM, a method that jointly tracks camera location and reconstructs non-rigid surfaces through differentiable rendering.
-
As of October 2026
Professor of Robot Vision
As of October 2026, he is Professor of Robot Vision in Imperial College London’s Department of Computing.
Career
- Since 2005Imperial College LondonLecturer
- 2000–2001University of Oxford
- 1998–2000National Institute of Advanced Industrial Science and Technology
Education
- 1998University of OxfordDPhil
- 1994University of OxfordBA in physics
Colleagues
Sources and credits
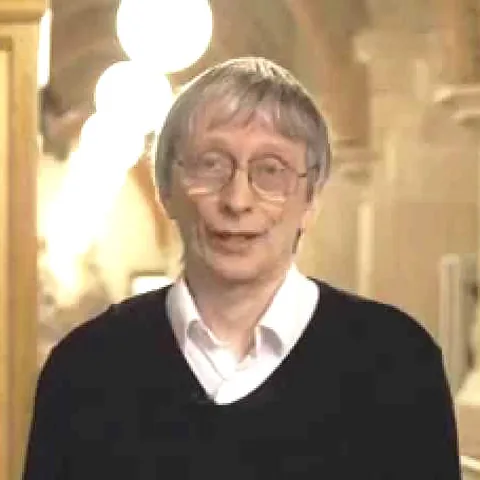
Photo: We have no published photo of Andrew Davison yet. Send us a free-licensed photo.
- Robotic vision | Events | Imperial College London
- Andrew Davison: Background
- Robots with vision | Faculty of Engineering | Imperial College London
- Dyson invests 5 million in DoC Professor's Robotic Vision Lab | Imperial News | Imperial College London
- Andrew Davison | Royal Academy of Engineering
- Robotic vision expert and fluid mechanic academic recognised as new Fellows | Imperial News | Imperial College London
- Two Imperial scientists elected as Fellows of the Royal Society | Imperial News | Imperial College London
- 4DTAM: Non-Rigid Tracking and Mapping via Dynamic Surface Gaussians
- Andrew Davison | About | Imperial College London