Stefan Leutenegger
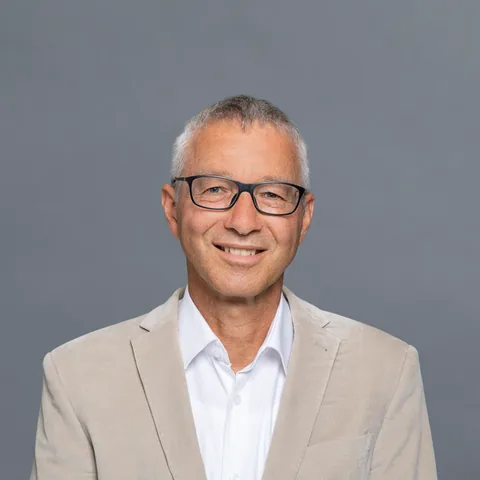
Stefan Leutenegger is a robotics researcher whose work connects mobile robotics with spatial AI and robot learning. He earned a gliding pilot license at 16 and three engineering degrees at ETH Zurich, then held robotics posts at Imperial College London and in machine learning for robotics at the Technical University of Munich. His research includes keyframe-based visual-inertial SLAM and SimpleMapping, a dense mapping method with deep multi-view stereo; he also co-founded SLAMcore. He is Associate Professor of Mobile Robotics at ETH Zurich and heads the Mobile Robotics Lab; a 2015 visual-inertial odometry paper he coauthored won the 2025 IJRR Test of Time Award.
- Now at
- ETH Zurich
- Works
- 167
- Citations
- 17,982
- h-index
- 40
Publication numbers from OpenAlex, as of 27 October 2026.
Timeline
-
By 2009
Gliding and engineering degrees
At 16, he earns a gliding pilot license, then studies mechanical engineering at ETH Zurich and receives a bachelor's degree in 2006 and a master's degree in 2009.
-
2013
Keyframe-based visual-inertial SLAM
In 2013, he and five collaborators present a keyframe-based visual-inertial SLAM method that tightly integrates visual measurements with inertial measurement unit (IMU) readings. Keyframes keep the optimization window bounded for real-time operation.
-
2014–2021
An ETH doctorate and Imperial robotics
He completes a doctorate in Mechatronics, Robotics and Automation Engineering at ETH Zurich in 2014 while training as a PhD student and research assistant in the Autonomous Systems Lab. From 2014 to 2021, he serves as Lecturer, Senior Lecturer and Reader in Robotics in Imperial College London's Department of Computing, where he leads the Smart Robotics Lab and researches autonomous robot navigation.
-
2016
Co-founding SLAMcore
He co-founds SLAMcore at Imperial College with Andrew Davison, Jacek Zienkiewicz and Owen Nicholson in 2016.
-
2021–2025
Machine learning for robotics
From 2021 to 2025, he serves as Assistant Professor for Machine Learning for Robotics at the Technical University of Munich.
-
2023
SimpleMapping dense mapping
In 2023, he coauthors SimpleMapping, a real-time visual-inertial dense-mapping method with deep multi-view stereo that builds 3D meshes from sequential monocular images and IMU readings. On challenging EuRoC scenarios, it improves F-score by 39.7% over existing systems.
-
2025
An IJRR Test of Time Award
In 2025, his 2015 paper with Simon Lynen, Michael Bosse, Roland Siegwart and Paul Furgale, “Keyframe-based Visual–Inertial Odometry Using Nonlinear Optimization,” wins the IJRR Test of Time Award.
-
Since 2025
Mobile robotics at ETH
He returns to ETH Zurich on 1 April 2025 as Associate Professor of Mobile Robotics in the Department of Mechanical and Process Engineering. By October 2025, he heads the Mobile Robotics Lab; he is also a PI in NCCR Automation at ETH Zurich, where his lab develops Spatial AI for mobile robots and works on mobile manipulation and robot learning.
Career
- Since 2025ETH ZurichAssociate Professor of Mobile Robotics
- NowETH ZurichHead of the Mobile Robotics Lab
- NowETH ZurichPrincipal Investigator in NCCR Automation
- Until 2021Imperial College LondonReader in Robotics
- 2021–2025Technical University of MunichAssistant Professor for Machine Learning for Robotics
- From 2016SLAMcoreCo-founder
- From 2014Imperial College LondonLecturer in Robotics
- ETH ZurichResearch Assistant in the Autonomous Systems Lab
- Imperial College LondonSenior Lecturer in Robotics
- Imperial College LondonHead of the Smart Robotics Lab
Education
- 2014ETH ZurichPhD in Mechatronics, Robotics and Automation Engineering
- 2009ETH ZurichMaster's Degree in Mechanical Engineering
- 2006ETH ZurichBachelor's Degree in Mechanical Engineering
Colleagues
Sources and credits
Photo: We have no published photo of Stefan Leutenegger yet. Send us a free-licensed photo.
- New professor of mobile robotics
- Keyframe-Based Visual-Inertial SLAM using Nonlinear Optimization
- Dr Stefan Leutenegger | Smart Robotics Lab
- About Us | Slamcore
- SimpleMapping: Real-Time Visual-Inertial Dense Mapping with Deep Multi-View Stereo
- 2025 IJRR Test of Time Award
- Inaugural Lecture: Making Robots Smart(er)
- Stefan Leutenegger | NCCR Automation