Umar Iqbal
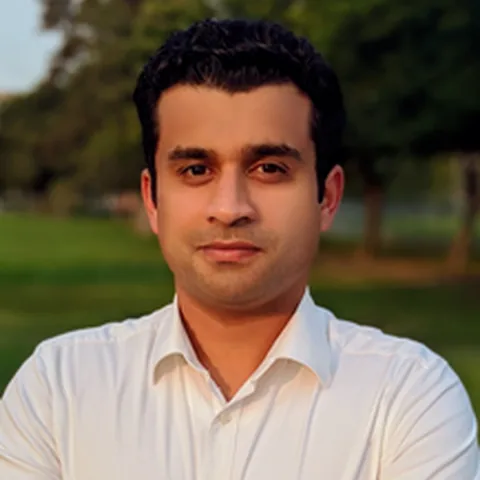
Umar Iqbal is senior research manager at NVIDIA Research and team lead of the Data-Driven AI for Robotics group, which studies how robots learn from human video and motion. He completed a computer engineering degree at COMSATS in Pakistan and an information technology master's at Tampere University of Technology in Finland, then a computer science PhD at the University of Bonn in 2018 on articulated human pose estimation. With Anton Milan and Juergen Gall he published PoseTrack at CVPR in July 2017, and in 2019 the dissertation received the DAGM MVTec Dissertation Award. PhysDiff, an ICCV 2023 oral on physics-guided motion diffusion, GEM, an ICCV 2025 highlight for generalist human motion, and SONIC, a Science Robotics 2026 paper on humanoid motion tracking, extended that work.
Timeline
-
2006–2013
Studies in Pakistan and Finland
From 2006 to 2010 he studies in Pakistan, and a 2009 undergraduate thesis takes up vehicle make and model recognition. In 2010 he receives a B.Sc. in computer engineering from COMSATS Institute of Information Technology and works there as a research associate in the Computer Vision Research Group during 2010 and 2011. From 2011 to 2013 he completes an M.Sc. in information technology at Tampere University of Technology in Finland and also works at Nokia Research Center as an external computer vision researcher.
-
2014–2018
A doctorate in Bonn
He works as a researcher at the University of Bonn from 2014 until 2018 under Juergen Gall and receives a PhD in computer science in 2018. The dissertation is Articulated Human Pose Estimation in Unconstrained Images and Videos.
-
July 2017
PoseTrack at CVPR
In July 2017 he, Anton Milan, and Juergen Gall present PoseTrack at CVPR in Hawaii. The paper treats multi-person pose estimation and tracking as one problem and introduces the Multi-Person PoseTrack dataset.
-
2019
The DAGM dissertation award
In 2019 he receives the DAGM MVTec Dissertation Award, given by the German Association for Pattern Recognition, for Articulated Human Pose Estimation in Unconstrained Images and Videos. The 2018 University of Bonn dissertation is graded summa cum laude.
-
2023
PhysDiff at ICCV
PhysDiff appears at ICCV 2023 as an oral, with Ye Yuan, Jiaming Song, Arash Vahdat, and Jan Kautz. A physics-based motion projection module inside the diffusion process projects each denoised motion toward a physically plausible result.
-
2025
GEM for human motion
In May 2025 GENMO appears on arXiv. ICCV 2025 lists the renamed model, GEM, as a highlight. He coauthors the generalist human-motion model with Jiefeng Li, Jinkun Cao, Haotian Zhang, Davis Rempe, Jan Kautz, and Ye Yuan, and it estimates and generates motion from video, text, and audio.
-
December 2025–2026
SONIC for humanoid control
In December 2025 the DAIR group releases SONIC, a generalist humanoid controller, and Science Robotics publishes the paper in 2026. He coauthors the motion-tracking model, which scales from 1.2 million to 42 million parameters and draws on more than 100 million frames from 700 hours of motion capture.
-
As of October 2026
Team lead of DAIR
As of October 2026 he is senior research manager at NVIDIA Research and team lead of the Data-Driven AI for Robotics group. The group is part of Learning and Perception Research and studies how robots learn skills from human video, motion capture, and large-scale demonstrations.
Sources and credits
Photo: umariqbal.info; Umar Iqbal; creator not stated. License: Not stated by source. Source: umariqbal.info. Cropped to a square and resized. Ask us to remove or replace this photo.
- Umar Iqbal
- Umar Iqbal | Research
- DAGM MVTec Dissertation Award
- CVPR 2017 Open Access Repository
- ICCV 2023 Open Access Repository
- GEM: A GENeralist Model for Human MOtion
- DAIR @ NVIDIA Research
- SONIC: Supersizing Motion Tracking for Natural Humanoid Whole-Body Control
- Umar Iqbal | DAIR @ NVIDIA Research