Songyuan Zhang
Songyuan Zhang coauthored Def-MARL. Def-MARL studies teams of robots that must complete a task while respecting safety constraints. The authors use an epigraph formulation to improve training stability and connect centralized training with distributed execution. They test eight tasks in two simulators and demonstrate coordination with Crazyflie quadcopters. The Def-MARL team, including Songyuan Zhang, received the RSS 2025 Outstanding Student Paper Award.
Timeline
-
2025
A shared Def-MARL contribution
Songyuan Zhang coauthored Def-MARL. Def-MARL studies teams of robots that must complete a task while respecting safety constraints. The authors use an epigraph formulation to improve training stability and connect centralized training with distributed execution. They test eight tasks in two simulators and demonstrate coordination with Crazyflie quadcopters.
-
2025
Conference recognition
The Def-MARL team, including Songyuan Zhang, received the RSS 2025 Outstanding Student Paper Award.
Sources and credits
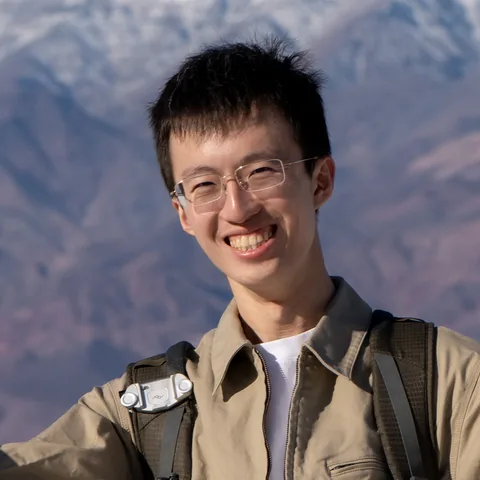
Photo: syzhang092218-source.github.io; Songyuan Zhang - Songyuan Zhang; creator not stated. License: Not stated by source. Source: syzhang092218-source.github.io. Cropped to a square and resized. Ask us to remove or replace this photo.