Reid Simmons
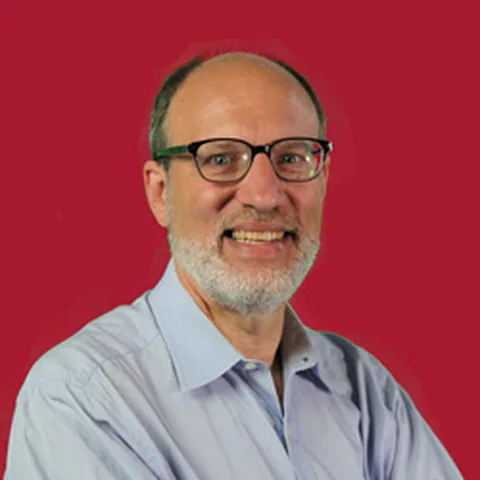
Reid Simmons studies reliable autonomous robots and human-robot interaction at Carnegie Mellon. With Vandi Verma, he published a 2004 method for tracking possible rover faults from noisy measurements. His robotics work also includes Xavier, Nomad, Grace, and the Valerie robot receptionist. In 2018, he was named director of the university’s new undergraduate AI degree program. His research includes probabilistic planning, coordination among robots and social interaction with people.
- Works
- 327
- Citations
- 15,385
- h-index
- 62
Publication numbers from OpenAlex, as of 14 October 2026.
Timeline
-
2004
Reasoning about rover faults
Simmons and Vandi Verma studied fault detection for planetary rovers, where communication delays can limit human intervention. Their March 2004 paper proposes a Monte Carlo method to track possible faults using noisy observations. The reported comparison uses a dynamic simulation of a six-wheel rover.
-
Robotics projects
Robots in social settings
Several robots are connected to Simmons’s work. Xavier navigated university hallways, and Nomad searched for meteorites in Antarctica. Grace moved through buildings and crowds. Valerie served as a robot receptionist, speaking with visitors and answering questions. The School of Drama collaborated on the receptionist’s character and interaction.
-
2018
Directing an AI degree program
On 10 May 2018, CMU named Simmons director of its new undergraduate AI degree program, scheduled to begin that fall. He describes a curriculum linking data, vision, language, and decision making, with computing and mathematical foundations. The program also emphasized ethics and social responsibility. The program was a university effort involving several departments.
-
As of October 2026
Reliable and cooperative robots
His research addresses robots that plan under uncertainty, detect problems, recover from errors and interact with people. His work also covers coordination among different robots, including forming teams and assigning tasks. He is a research professor.
Sources and credits
Photo: csd.cmu.edu; creator not stated. License: Not stated by source. Source: csd.cmu.edu. Cropped to a square and resized. Ask us to remove or replace this photo.