Jens Kober
Kober is a professor in Stuttgart and holds a joint appointment at Fraunhofer IPA. His research covers motor-skill learning, reinforcement learning, imitation and interactive robot training. Kober co-authored the RSS 2026 study Set-Supervised Diffusion Policy. The work concerns learning action sequences through corrections, connecting robot-policy learning with human input. Kober also co-authored a Nature Communications study using active inference to model collision-avoidance behavior in human drivers. This is research on interaction and uncertainty in driving.
- Now at
- University of Stuttgart
- Works
- 200
- Citations
- 8,867
- h-index
- 35
Publication numbers from OpenAlex, as of 14 October 2026.
Timeline
-
As of October 2026
Learning and Interactive Robots
Kober is a professor in Stuttgart and holds a joint appointment at Fraunhofer IPA. His research covers motor-skill learning, reinforcement learning, imitation and interactive robot training.
-
2026
Learning from corrections
Kober co-authored the RSS 2026 study Set-Supervised Diffusion Policy. The work concerns learning action sequences through corrections, connecting robot-policy learning with human input.
-
2026
Models of collision avoidance
Kober also co-authored a Nature Communications study using active inference to model collision-avoidance behavior in human drivers. This is research on interaction and uncertainty in driving.
Sources and credits
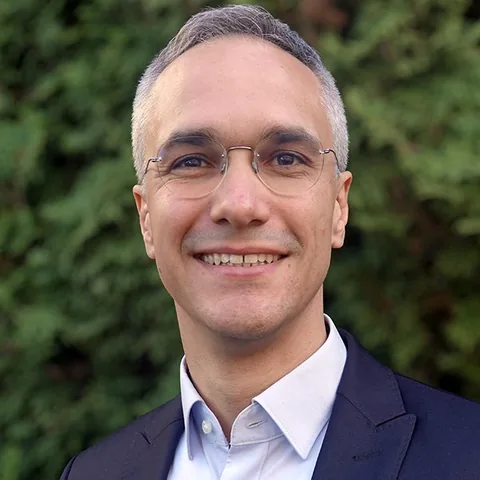
Photo: www.jenskober.de; creator not stated. License: Not stated by source. Source: jenskober.de. Cropped to a square and resized. Ask us to remove or replace this photo.