Jean-Claude Latombe
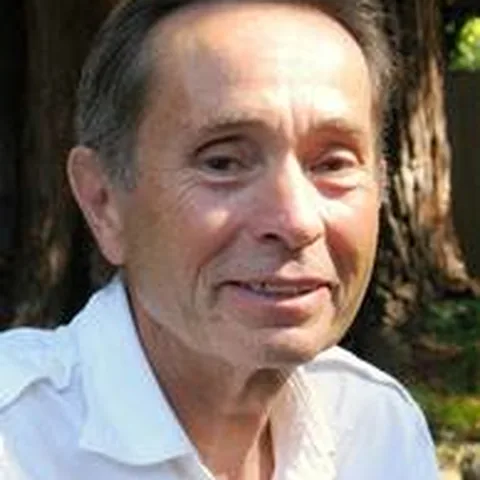
Jean-Claude Latombe develops robot motion planning, including shared research on probabilistic roadmaps and geometric search. Latombe earned electrical engineering and computing degrees at Grenoble in 1969 and 1970. He earned a computer science doctorate in 1977 with a thesis applying AI to design automation. Latombe chaired Stanford computer science from 1997 to 2001. His research includes exact collision checking of robot paths in 2004 and adaptive collision checking for articulated robots in 2005, with Fabian Schwarzer and Mitul Saha. These are specific later planning publications.
- Works
- 172
- Citations
- 18,743
- h-index
- 53
Publication numbers from OpenAlex, as of 14 October 2026.
Timeline
-
1969–1977
Engineering and AI training
Latombe’s career includes electrical engineering and computing degrees at Grenoble in 1969 and 1970. He earned a computer science doctorate in 1977 with a thesis applying AI to design automation.
-
1984–1991
Research settings and a planning book
Latombe led ITMI, a robotics, vision and AI company, from 1984 to 1987. He joined Stanford as an associate professor in 1987. Latombe published Robot Motion Planning in 1991, a named book within his technical research program.
-
1996
Probabilistic roadmaps
Lydia Kavraki, Petr Švestka, Latombe and Mark Overmars published shared work on probabilistic roadmaps for path planning in high-dimensional configuration spaces. The journal paper appeared in 1996. Related publications studied random sampling and connectivity.
-
1997–2005
Leadership and collision checking
Latombe chaired Stanford computer science from 1997 to 2001. His research includes exact collision checking of robot paths in 2004 and adaptive collision checking for articulated robots in 2005, with Fabian Schwarzer and Mitul Saha.
Sources and credits
Photo: ai.stanford.edu; page title not stated; creator not stated. License: Not stated by source. Source: ai.stanford.edu. Cropped to a square and resized. Ask us to remove or replace this photo.