Hongbiao Zhu
Zhu studied odor-source localization using particle filtering and information entropy in 2020. His research covers autonomous exploration and source localization. Hongbiao Zhu coauthored TARE. A robot exploring an unknown building must select useful routes while it builds a map. TARE uses detailed local planning and a coarser global plan to explore complex three-dimensional environments. The team tested its method with ground and aerial robots indoors and outdoors. TARE received the RSS 2021 Best Paper and Best Systems Paper awards, with Zhu among its authors.
- Works
- 28
- Citations
- 947
- h-index
- 12
Publication numbers from OpenAlex, as of 14 October 2026.
Timeline
-
2020
Locating an odor source
Zhu studied odor-source localization using particle filtering and information entropy in 2020. His research covers autonomous exploration and source localization.
-
2021
A shared TARE contribution
Hongbiao Zhu coauthored TARE. A robot exploring an unknown building must select useful routes while it builds a map. TARE uses detailed local planning and a coarser global plan to explore complex three-dimensional environments. The team tested its method with ground and aerial robots indoors and outdoors.
-
2021
Conference recognition
TARE received the RSS 2021 Best Paper and Best Systems Paper awards, with Zhu among its authors.
Sources and credits
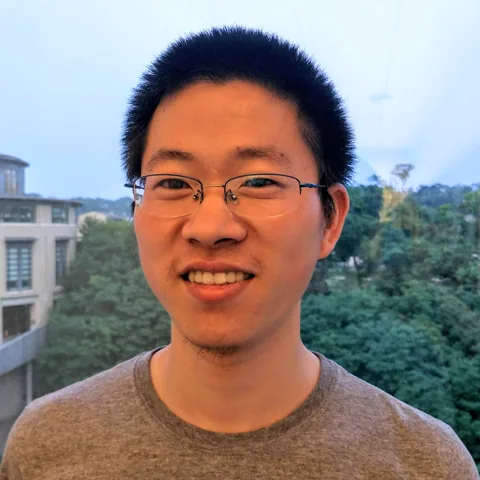
Photo: www.hongbiaoz.com; creator not stated. License: Not stated by source. Source: hongbiaoz.com. Cropped to a square and resized. Ask us to remove or replace this photo.