Yuval Tassa
Yuval Tassa coauthored MuJoCo Playground. MuJoCo Playground is an open-source framework for simulation, policy training and transfer to physical robots. It combines MJX physics, a batch renderer and training environments. The team demonstrated tasks for quadrupeds, humanoids, hands and arms, including transfer from state and pixel observations. This is a shared software and research contribution. The project joins efficient physics simulation, rendering and training environments to support robot learning. Tassa and the MuJoCo Playground team received the RSS 2025 Outstanding Demo Paper Award.
- Works
- 65
- Citations
- 19,832
- h-index
- 34
Publication numbers from OpenAlex, as of 14 October 2026.
Timeline
-
2025
A shared MuJoCo Playground contribution
Yuval Tassa coauthored MuJoCo Playground. MuJoCo Playground is an open-source framework for simulation, policy training and transfer to physical robots. It combines MJX physics, a batch renderer and training environments. The team demonstrated tasks for quadrupeds, humanoids, hands and arms, including transfer from state and pixel observations. This is a shared software and research contribution.
-
2025
Defined project contribution
Tassa coauthored the framework. The project joins efficient physics simulation, rendering and training environments to support robot learning.
-
2025
Conference recognition
Tassa and the MuJoCo Playground team received the RSS 2025 Outstanding Demo Paper Award.
Sources and credits
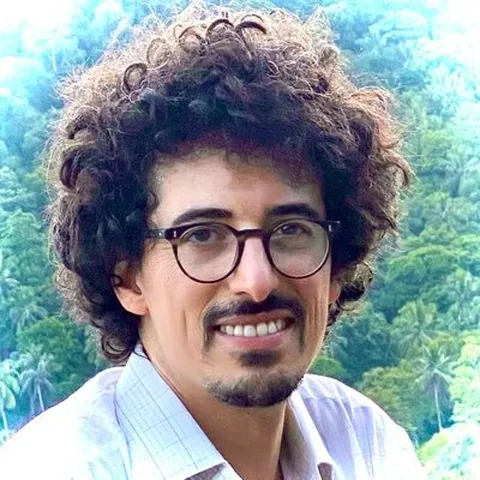
Photo: cr2-icra.github.io; CR2@ICRA2026 | cr2-icra; creator not stated. License: Not stated by source. Source: cr2-icra.github.io. Cropped to a square and resized. Ask us to remove or replace this photo.