Weizhe Chen
Weizhe Chen researches active robot learning and information gathering. At Indiana University, he worked with Lantao Liu and Roni Khardon and defended his doctorate in April 2024. He coauthored the Attentive Kernel method presented at RSS 2022, which learns spatial models whose variability can change across locations. The conference paper describes how better uncertainty estimates can guide a robot toward useful measurements. His later research includes online attentive mapping and planning with uncertain distributions. The work links probabilistic learning with robotic sensing.
- Works
- 70
- Citations
- 1,472
- h-index
- 20
Publication numbers from OpenAlex, as of 14 October 2026.
Timeline
-
2019
Planning and environmental monitoring
His 2019 work included shared research on multi-objective Monte Carlo tree search for informative planning and ocean monitoring with streaming samples. These projects connect planning decisions with the collection of useful environmental observations.
-
2022
Attentive Kernel
Chen coauthored Attentive Kernel with Roni Khardon and Lantao Liu. The paper used nonstationary Gaussian-process kernels and tested them in elevation mapping and an autonomous surface vehicle.
-
2022–2023
Research recognition and extensions
His coauthored Attentive Kernel paper received the RSS 2022 Best Student Paper Award. His 2023 research included nonstationary Gaussian processes and planning with propagated distributions.
-
April–June 2024
Doctoral defence and online mapping
Chen defended his dissertation on active robot learning in April 2024, and POAM, probabilistic online attentive mapping, was accepted in June 2024.
Sources and credits
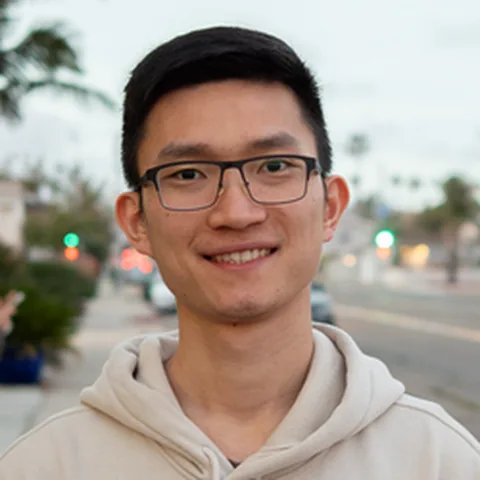
Photo: wchen-robotics.com; Weizhe Chen profile photograph; creator not stated. License: Not stated by source. Source: wchen-robotics.com. Cropped to a square and resized. Ask us to remove or replace this photo.