Vincent Sitzmann
Vincent Sitzmann earned a Stanford doctorate with Gordon Wetzstein. His research covers differentiable rendering, neural implicit representations and generative modeling of scenes. His 2025 work includes controlling diverse robots by inferring Jacobian fields with deep networks. His work also includes Large Video Planner and History-Guided Video Diffusion, connecting video models with planning and control. Sitzmann is an MIT associate professor and leads the Scene Representation Group. His 2026 research includes video consistency and video-based generalist robot policies as part of a program in embodied intelligence.
- Works
- 76
- Citations
- 5,406
- h-index
- 25
Publication numbers from OpenAlex, as of 14 October 2026.
Timeline
-
Research background
Representing three-dimensional scenes
Vincent Sitzmann earned a Stanford doctorate with Gordon Wetzstein. His research covers differentiable rendering, neural implicit representations and generative modeling of scenes.
-
2025
From vision to robot actions
His 2025 work includes controlling diverse robots by inferring Jacobian fields with deep networks. His work also includes Large Video Planner and History-Guided Video Diffusion, connecting video models with planning and control.
-
As of October 2026
Scene Representation Group
Sitzmann is an MIT associate professor and leads the Scene Representation Group. His 2026 research includes video consistency and video-based generalist robot policies as part of a program in embodied intelligence.
Sources and credits
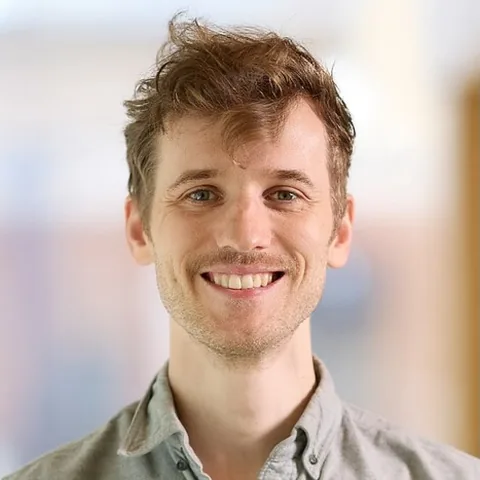
Photo: www.vincentsitzmann.com; Vincent Sitzmann profile photograph; creator not stated. License: Not stated by source. Source: vincentsitzmann.com. Cropped to a square and resized. Ask us to remove or replace this photo.