Oswin So
So completed a summer 2021 behavior-planning internship at Aurora, working on cost-function learning. So studied at Georgia Tech before doctoral research with Chuchu Fan at MIT. So researches Hamilton–Jacobi reachability and control barrier functions for reinforcement learning. These methods connect learned behavior with constraints for multi-agent systems and aircraft. Oswin So coauthored Def-MARL. Def-MARL studies teams of robots that must complete a task while respecting safety constraints. The authors use an epigraph formulation to improve training stability and connect centralized training with distributed execution. They test eight tasks in two simulators and demonstrate coordination with Crazyflie quadcopters. Oswin So and the Def-MARL team received the RSS 2025 Outstanding Student Paper Award.
- Works
- 42
- Citations
- 222
- h-index
- 7
Publication numbers from OpenAlex, as of 14 October 2026.
Timeline
-
2021
Autonomous-driving planning
So completed a summer 2021 behavior-planning internship at Aurora, working on cost-function learning. So studied at Georgia Tech before doctoral research with Chuchu Fan at MIT.
-
As of October 2026
Learning safe control
So researches Hamilton–Jacobi reachability and control barrier functions for reinforcement learning. These methods connect learned behavior with constraints for multi-agent systems and aircraft.
-
2025
A shared Def-MARL contribution
Oswin So coauthored Def-MARL. Def-MARL studies teams of robots that must complete a task while respecting safety constraints. The authors use an epigraph formulation to improve training stability and connect centralized training with distributed execution. They test eight tasks in two simulators and demonstrate coordination with Crazyflie quadcopters.
-
2025
Conference recognition
Oswin So and the Def-MARL team received the RSS 2025 Outstanding Student Paper Award.
Sources and credits
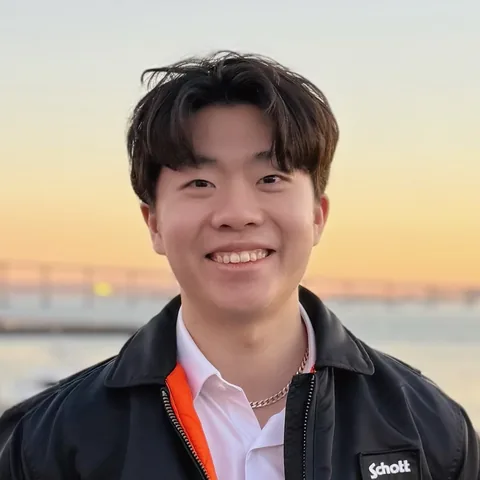
Photo: oswinso.xyz; Oswin So profile photograph; creator not stated. License: Not stated by source. Source: oswinso.xyz. Cropped to a square and resized. Ask us to remove or replace this photo.