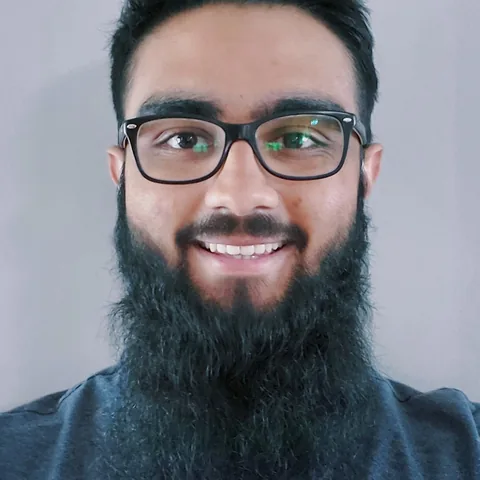
Mustafa Haiderbhai
Haiderbhai coauthored pix2xray, a study using generative adversarial networks to create X-ray images. He defended a master’s thesis in August and began a computer-science PhD at Toronto in September. Haiderbhai had a machine-learning residency at X in March 2022 and studied simulation-to-real transfer with the da Vinci Research Kit in 2022. His research links simulation, reinforcement learning and medical robotics. Mustafa Haiderbhai coauthored MuJoCo Playground. MuJoCo Playground is an open-source framework for simulation, policy training and transfer to physical robots. It combines MJX physics, a batch renderer and training environments. The team demonstrated tasks for quadrupeds, humanoids, hands and arms, including transfer from state and pixel observations. Haiderbhai developed Madrona-MJX features and, with Jing Yuan Luo, integrated them into Playground. This connects image rendering with robot-policy learning. The RSS 2025 Outstanding Demo Paper Award recognized Mustafa Haiderbhai and the MuJoCo Playground team.
- Now at
- University of Toronto
- Works
- 12
- Citations
- 77
- h-index
- 6
Publication numbers from OpenAlex, as of 14 October 2026.
Timeline
-
2020
Synthetic medical images and doctoral research
Haiderbhai coauthored pix2xray, a study using generative adversarial networks to create X-ray images. He defended a master’s thesis in August and began a computer-science PhD at Toronto in September.
-
2022
Wearable and surgical robotics
Haiderbhai began a machine-learning residency at X in March 2022 and studied simulation-to-real transfer with the da Vinci Research Kit in 2022. His research links simulation, reinforcement learning and medical robotics.
-
2025
MuJoCo Playground
Mustafa Haiderbhai coauthored MuJoCo Playground. MuJoCo Playground is an open-source framework for simulation, policy training and transfer to physical robots. It combines MJX physics, a batch renderer and training environments. The team demonstrated tasks for quadrupeds, humanoids, hands and arms, including transfer from state and pixel observations.
-
2025
Defined project contribution
Haiderbhai developed Madrona-MJX features and, with Jing Yuan Luo, integrated them into Playground. This connects image rendering with robot-policy learning.
-
2025
Conference recognition
The RSS 2025 Outstanding Demo Paper Award recognized Mustafa Haiderbhai and the MuJoCo Playground team.
Sources and credits
Photo: www.mustafahdb.com; creator not stated. License: Not stated by source. Source: mustafahdb.com. Cropped to a square and resized. Ask us to remove or replace this photo.