Bob McGrew
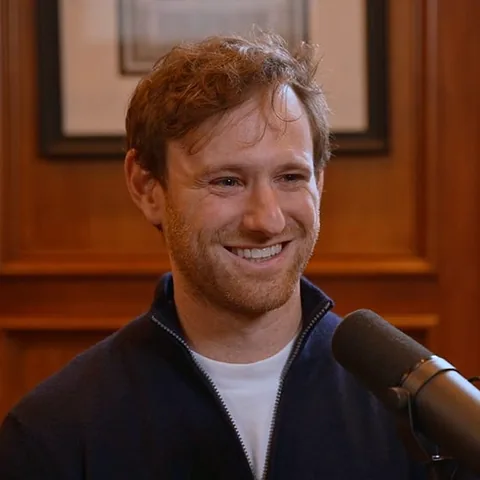
Bob McGrew is a technology builder with shared research contributions to robotics and code generation at OpenAI. He studied at Stanford from 2002 to 2005 and moved to Palantir after taking leave. His papers include Hindsight Experience Replay, learning dexterous control with a robot hand, and solving a Rubik’s Cube with that hand. These projects examined learning with sparse rewards and transferring policies from simulation to physical equipment. He later co-authored Codex, which tested code generation through functional checks. He was an advisor to Thinking Machines Lab in 2025.
- Works
- 13
Publication numbers from OpenAlex, as of 14 October 2026. Citations and h-index are hidden because this OpenAlex record may be incomplete or mix in other authors.
Timeline
-
2002–2005
Study at Stanford
McGrew studied at Stanford from 2002 to 2005.
-
July 2017
Learning from sparse rewards
McGrew co-authored Hindsight Experience Replay in 2017.
-
2018
Dexterous robot control
McGrew co-authored dexterous robot hand research in 2018.
-
2019
A robot solves a cube
McGrew co-authored robot Rubik’s Cube research in 2019.
-
2021
Code generation
McGrew co-authored Codex in 2021.
-
2025
Thinking Machines Lab advisor
McGrew was an advisor to Thinking Machines Lab in 2025.
Sources and credits
Photo: American Optimist / Joe Lonsdale; Bob McGrew interview portrait. License: Not stated by source. Source: blog.joelonsdale.com. Cropped to a square and resized. Ask us to remove or replace this photo.