Kevin Zakka
Kevin Zakka researches robot learning, simulation and transfer to physical robots. His shared projects include dexterous control and an open simulation framework. Zakka coauthored the CoRL 2021 paper XIRL on cross-embodiment inverse reinforcement learning. The project studies robot learning across different bodies. He coauthored CoRL 2023 work on RoboPianist, which applies deep reinforcement learning to dexterous piano playing. Zakka co-authored MuJoCo Playground with collaborators. The original paper presents an open framework built with MJX that combines simulation, rendering and training environments for robot learning and sim-to-real transfer.
- Works
- 12
- Citations
- 149
- h-index
- 5
Publication numbers from OpenAlex, as of 14 October 2026.
Timeline
-
2021
Learning across embodiments
Zakka coauthored the CoRL 2021 paper XIRL on cross-embodiment inverse reinforcement learning. The project studies robot learning across different bodies.
-
2023
Dexterous piano playing
He coauthored CoRL 2023 work on RoboPianist, which applies deep reinforcement learning to dexterous piano playing.
-
2025
MuJoCo Playground
Zakka co-authored MuJoCo Playground with collaborators. The original paper presents an open framework built with MJX that combines simulation, rendering and training environments for robot learning and sim-to-real transfer.
-
As of October 2026
Simulation and whole-body control
His doctoral research at Berkeley with Pieter Abbeel focuses on humanoid whole-body control, data priors and system identification.
Sources and credits
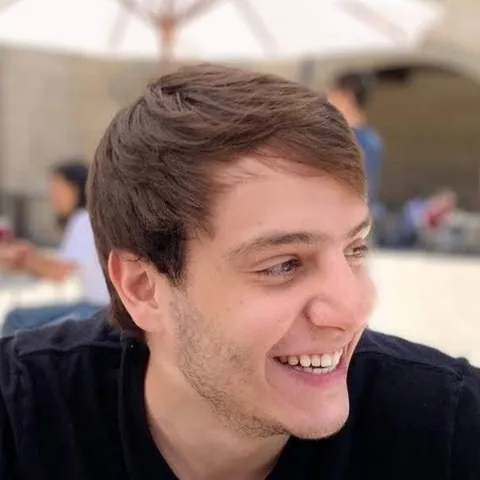
Photo: kzakka.com; creator not stated. License: CC BY-NC-SA 4.0 (site content statement; portrait scope not separately stated). Source: kzakka.com. Cropped to a square and resized. Ask us to remove or replace this photo.