Ken Goldberg
Goldberg’s work includes the Dex-Net program for learning robust grasps. He also works at AUTOLab and is a co-founder of Ambi Robotics and Jacobi Robotics. Ken Goldberg coauthored Autonomously Untangling Long Cables. The study combines two robot arms, specialized grippers and motion primitives to untangle cables up to 2.7 metres long. Its SGTM algorithm manages slack and uses sliding and grasping actions. Experiments reported 67 percent success on isolated overhand and figure-eight knots and 50 percent on more complex configurations. Ken Goldberg and the Autonomously Untangling Long Cables team received the RSS 2022 Best Systems Paper Award.
- Now at
- University of California, Berkeley, Ambi Robotics and Jacobi Robotics
- Works
- 665
- Citations
- 25,509
- h-index
- 60
Publication numbers from OpenAlex, as of 14 October 2026.
Timeline
-
As of October 2026
Learning robot grasping
Goldberg’s work includes the Dex-Net program for learning robust grasps. He also works at AUTOLab and is a co-founder of Ambi Robotics and Jacobi Robotics.
-
2022
A shared Autonomously Untangling Long Cables contribution
Ken Goldberg coauthored Autonomously Untangling Long Cables. The study combines two robot arms, specialized grippers and motion primitives to untangle cables up to 2.7 metres long. Its SGTM algorithm manages slack and uses sliding and grasping actions. Experiments reported 67 percent success on isolated overhand and figure-eight knots and 50 percent on more complex configurations.
-
2022
Conference recognition
Ken Goldberg and the Autonomously Untangling Long Cables team received the RSS 2022 Best Systems Paper Award.
Sources and credits
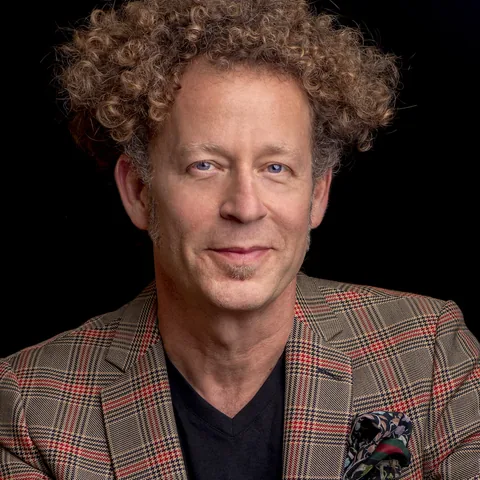
Photo: Notkengoldberg, via Wikimedia Commons. License: CC BY-SA 4.0. Source: commons.wikimedia.org. Cropped to a square and resized. Ask us to remove or replace this photo.
