Ellen Novoseller
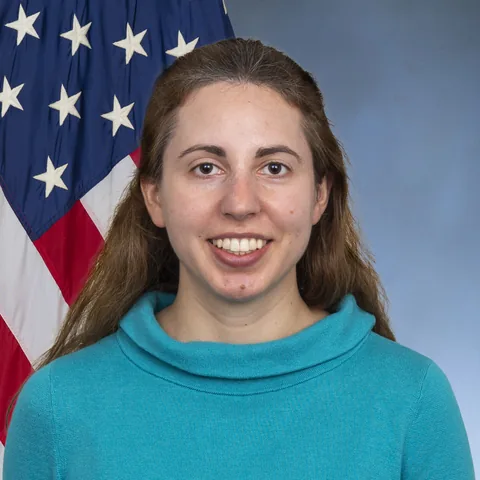
Ellen Novoseller completed a 2020 Caltech dissertation on online learning from human feedback and exoskeleton gait optimisation. She later worked in Berkeley’s AUTOLAB and at the Army Research Laboratory. Her research includes preference-based learning, interactive imitation learning, and multi-agent coordination. A paper first submitted in 2019 introduced CoSpar for learning exoskeleton users’ preferences. She also co-authored Autonomously Untangling Long Cables at RSS 2022.
- Now at
- United States Army Futures Command
- Works
- 31
- Citations
- 393
- h-index
- 12
Publication numbers from OpenAlex, as of 14 October 2026.
Timeline
-
2019–2020
Learning gait preferences
Novoseller co-authored a paper first submitted in 2019 and presented at ICRA 2020. The CoSpar method asks users to compare trials and suggest improvements. It studies how those preferences can guide exoskeleton gait parameters, with prototype experiments described by the authors.
-
2020
A doctorate on human feedback
She completed a 2020 dissertation at Caltech on online learning from human feedback and exoskeleton gait optimisation. It names Yisong Yue and Joel Burdick as advisers. Her training spans control and dynamical systems and connects to preference-based learning.
-
2022
Untangling long cables
She co-authored Autonomously Untangling Long Cables at RSS 2022. The paper presents a robot system that uses perception and manipulation to address cable knots.
-
As of October 2026
Interactive and multi-agent learning
She worked at Berkeley AUTOLAB after Caltech and later held roles at Army Research Laboratory. Her current research covers human-AI interaction, sequential decisions, robot learning, and multi-agent coordination.
Sources and credits
Photo: ernovoseller.github.io; creator not stated. License: Not stated by source. Source: ernovoseller.github.io. Cropped to a square and resized. Ask us to remove or replace this photo.