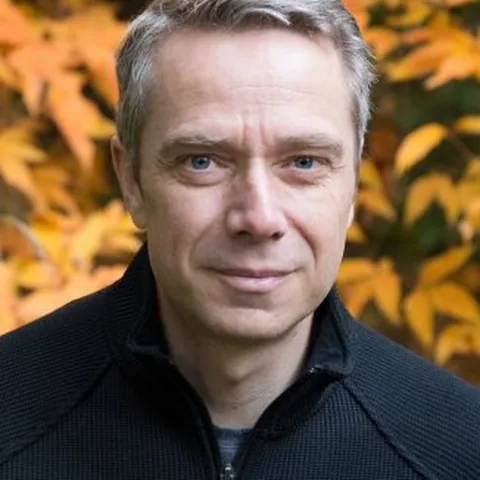
Dieter Fox
Dieter Fox researches probabilistic robotics and robot perception. He earned his Bonn doctorate in 1998 and joined Washington’s faculty in 2000. His shared Monte Carlo Localization work represents uncertainty about a robot’s position using particles. He later studied adaptive particle sampling and contributed to wireless-signal localization and mapping. AAAI elected him a Fellow in 2011. His continuing interests include state estimation, control and manipulation.
- Works
- 430
- Citations
- 43,644
- h-index
- 103
Publication numbers from OpenAlex, as of 14 October 2026.
Timeline
-
1998–2000
From Bonn to Washington
Fox earned his Bonn doctorate in 1998 and joined Washington’s faculty in autumn 2000. His research covers robotics, state estimation, perception and manipulation. These interests connect how a robot senses its surroundings with how it chooses and performs actions.
-
1999
Monte Carlo localization
Fox coauthored the 1999 Monte Carlo Localization paper with Wolfram Burgard, Frank Dellaert and Sebastian Thrun. Particle sets represent uncertainty about a mobile robot’s position. Sensor observations update those possibilities as the robot localizes itself in a map.
-
2001–2007
Adaptive samples and wireless location
Fox published papers on KLD-sampling in 2001 and 2003. The method adapts the number of particles to uncertainty. In 2006 and 2007, Fox and collaborators used Gaussian-process models of wireless signal strengths for location estimation and mapping.
-
2011 and later
Recognition and continued robotics research
AAAI elected Fox a Fellow in 2011. Fox works on perception, control and manipulation and is affiliated with Washington and Ai2.
Sources and credits
Photo: homes.cs.washington.edu; creator not stated. License: Not stated by source. Source: homes.cs.washington.edu. Cropped to a square and resized. Ask us to remove or replace this photo.